Blu-Sub Piranha
Eight-thruster autonomous underwater vehicle
- Project year
- 2026
- Status
- Ongoing
A six-degree-of-freedom AUV driven by eight Blu-Sub thrusters with built-in ESCs, a Jetson Orin Nano main computer, RealSense vision and a Waterlinked DVL.
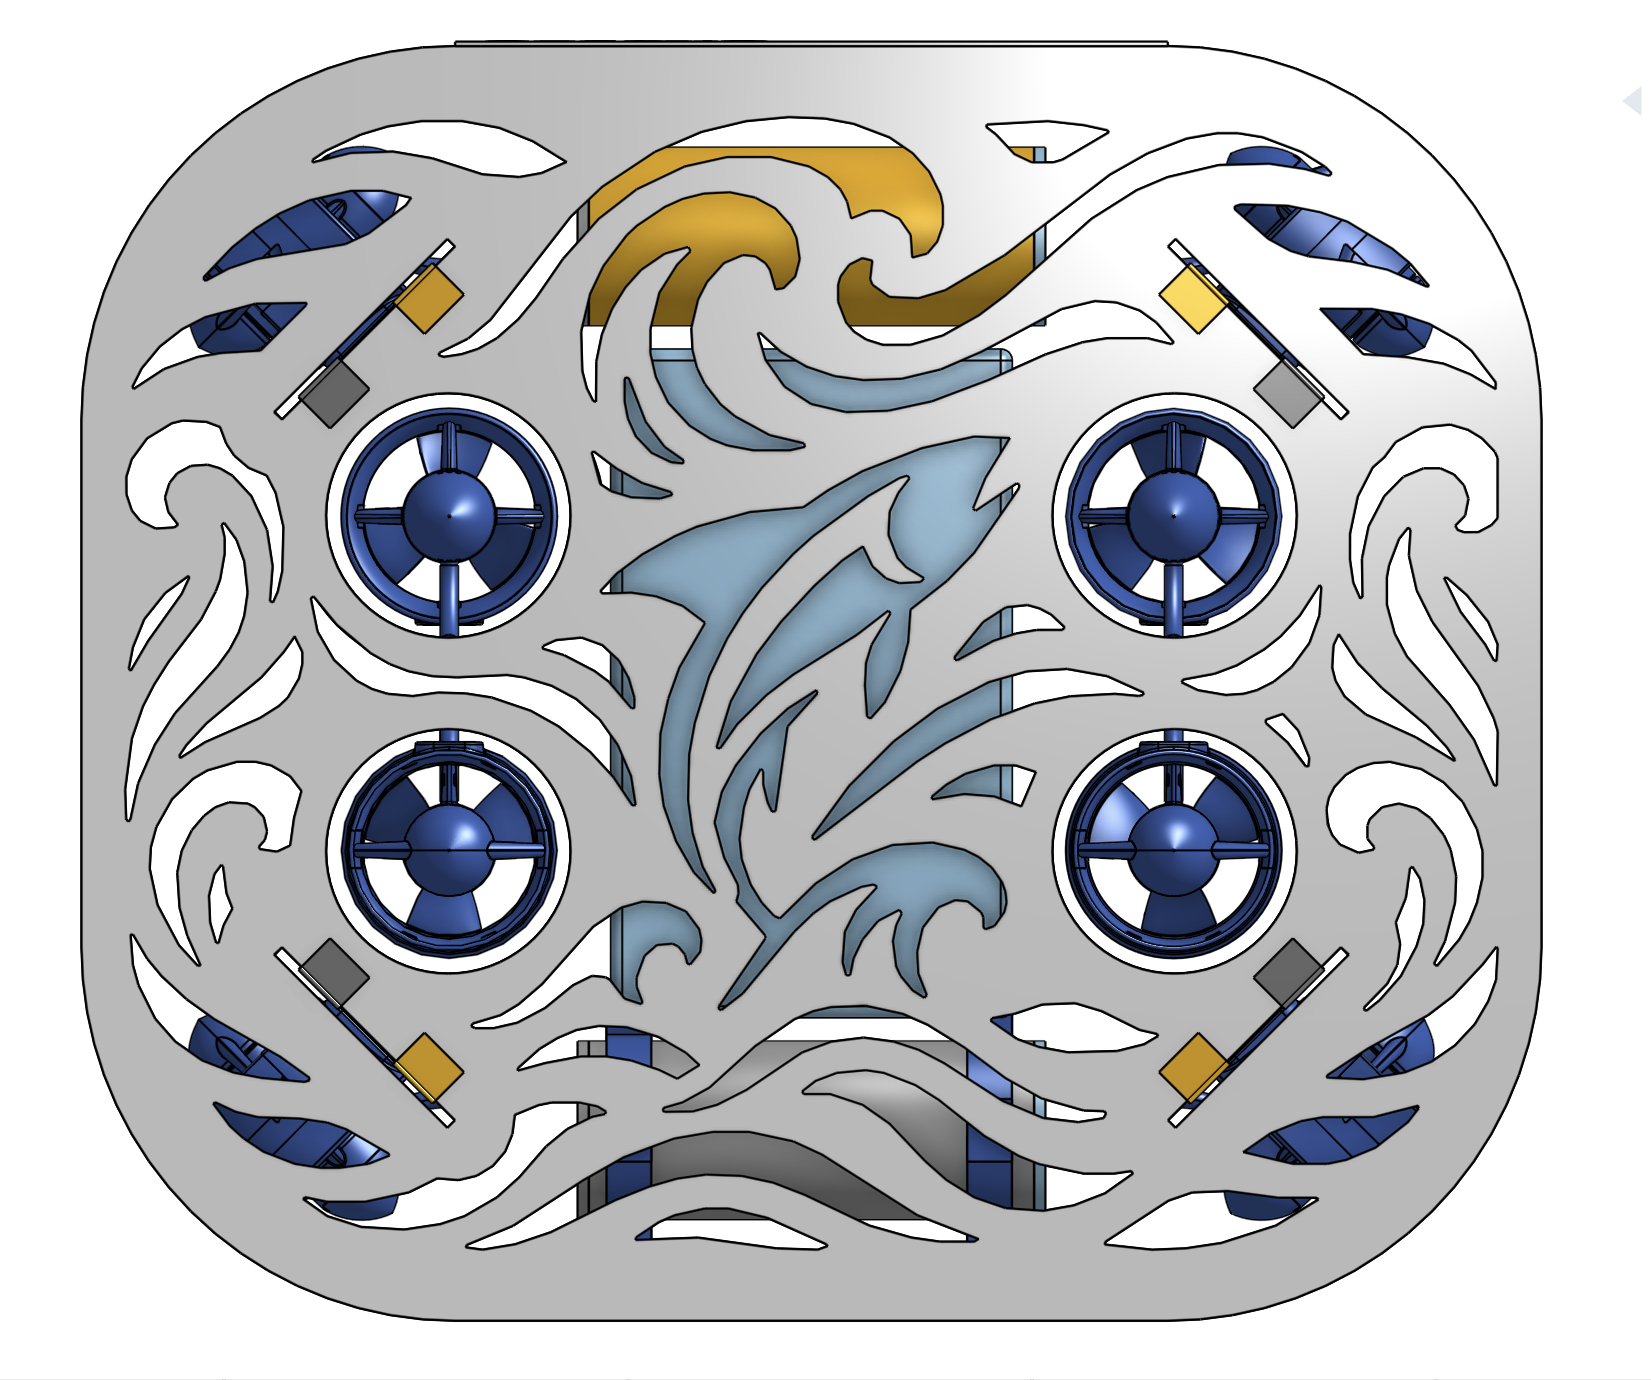
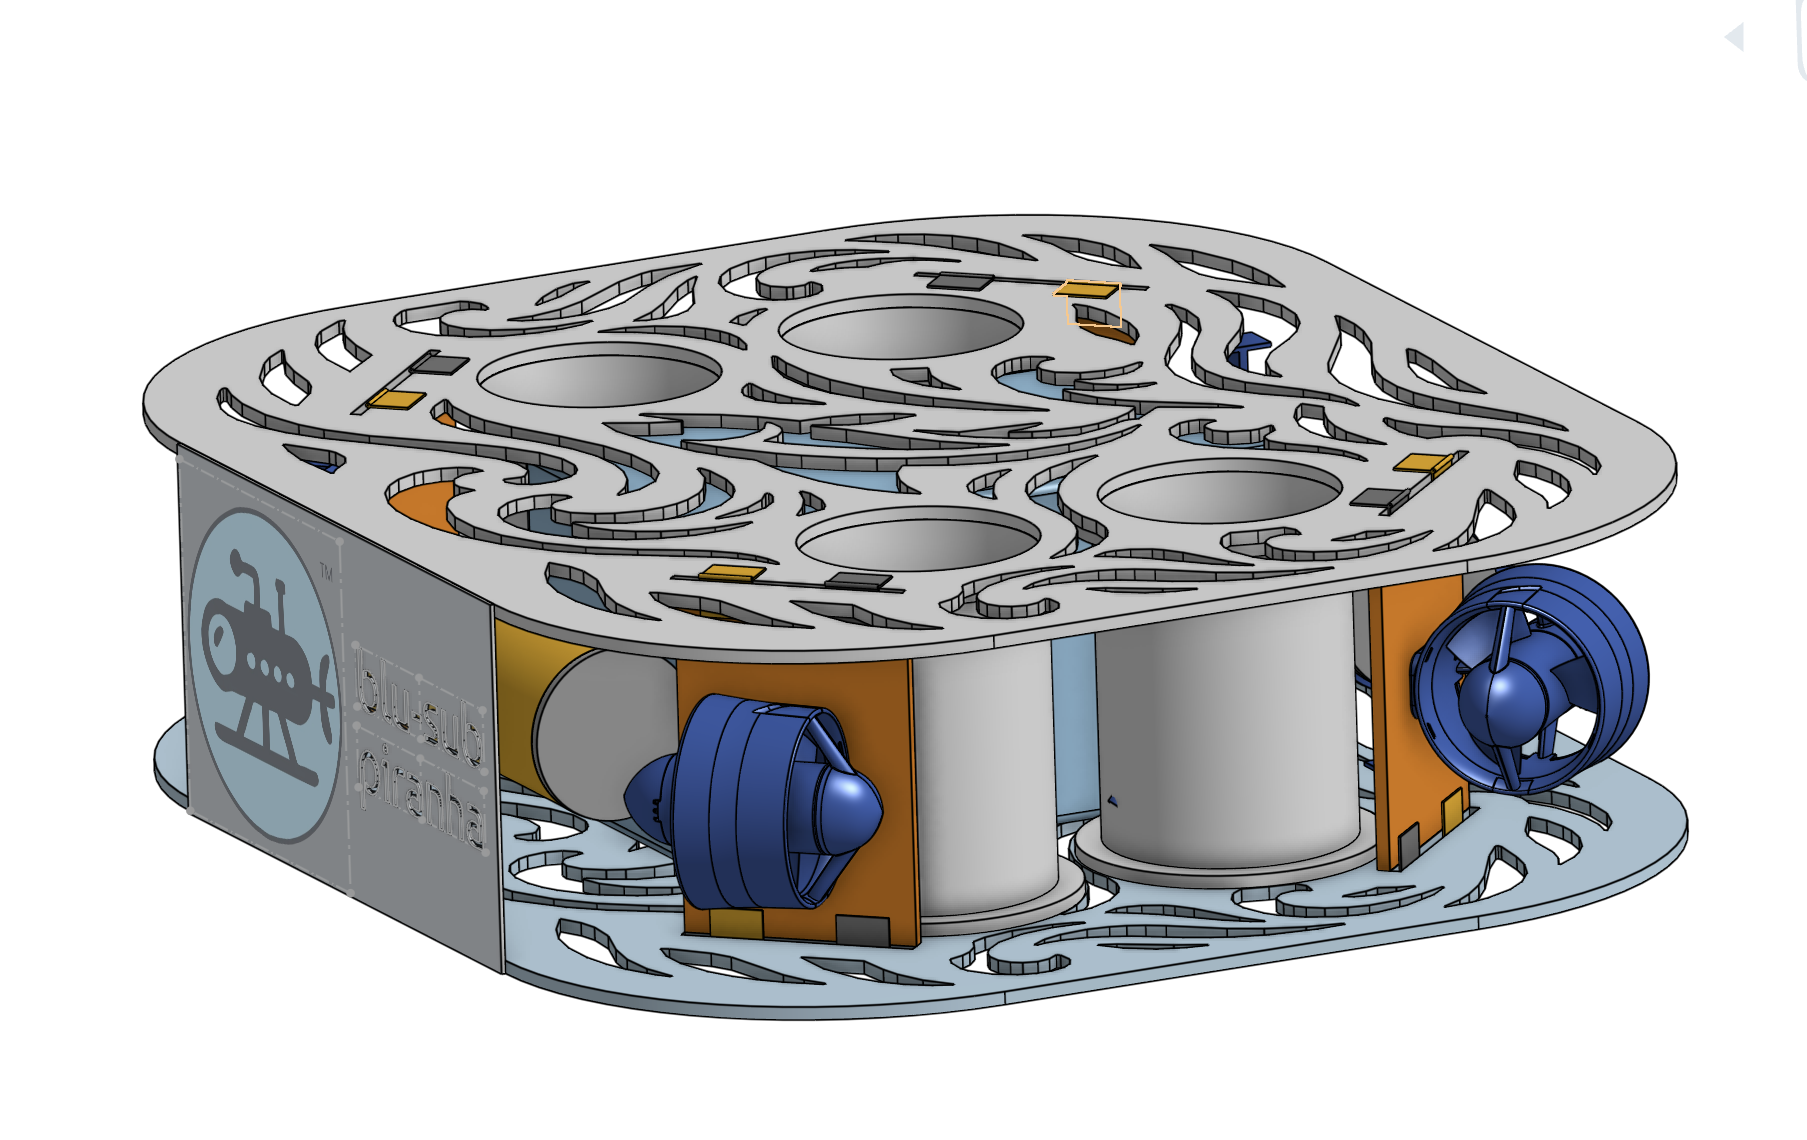
Blu-Sub Piranha is an autonomous underwater vehicle (AUV) built around an eight-thruster layout that gives it full six-degree-of-freedom control — surge, sway, heave, roll, pitch and yaw. That authority lets the vehicle hold station, translate in any direction and rotate in place, which is essential for precise inspection tasks and competition-style mission elements.
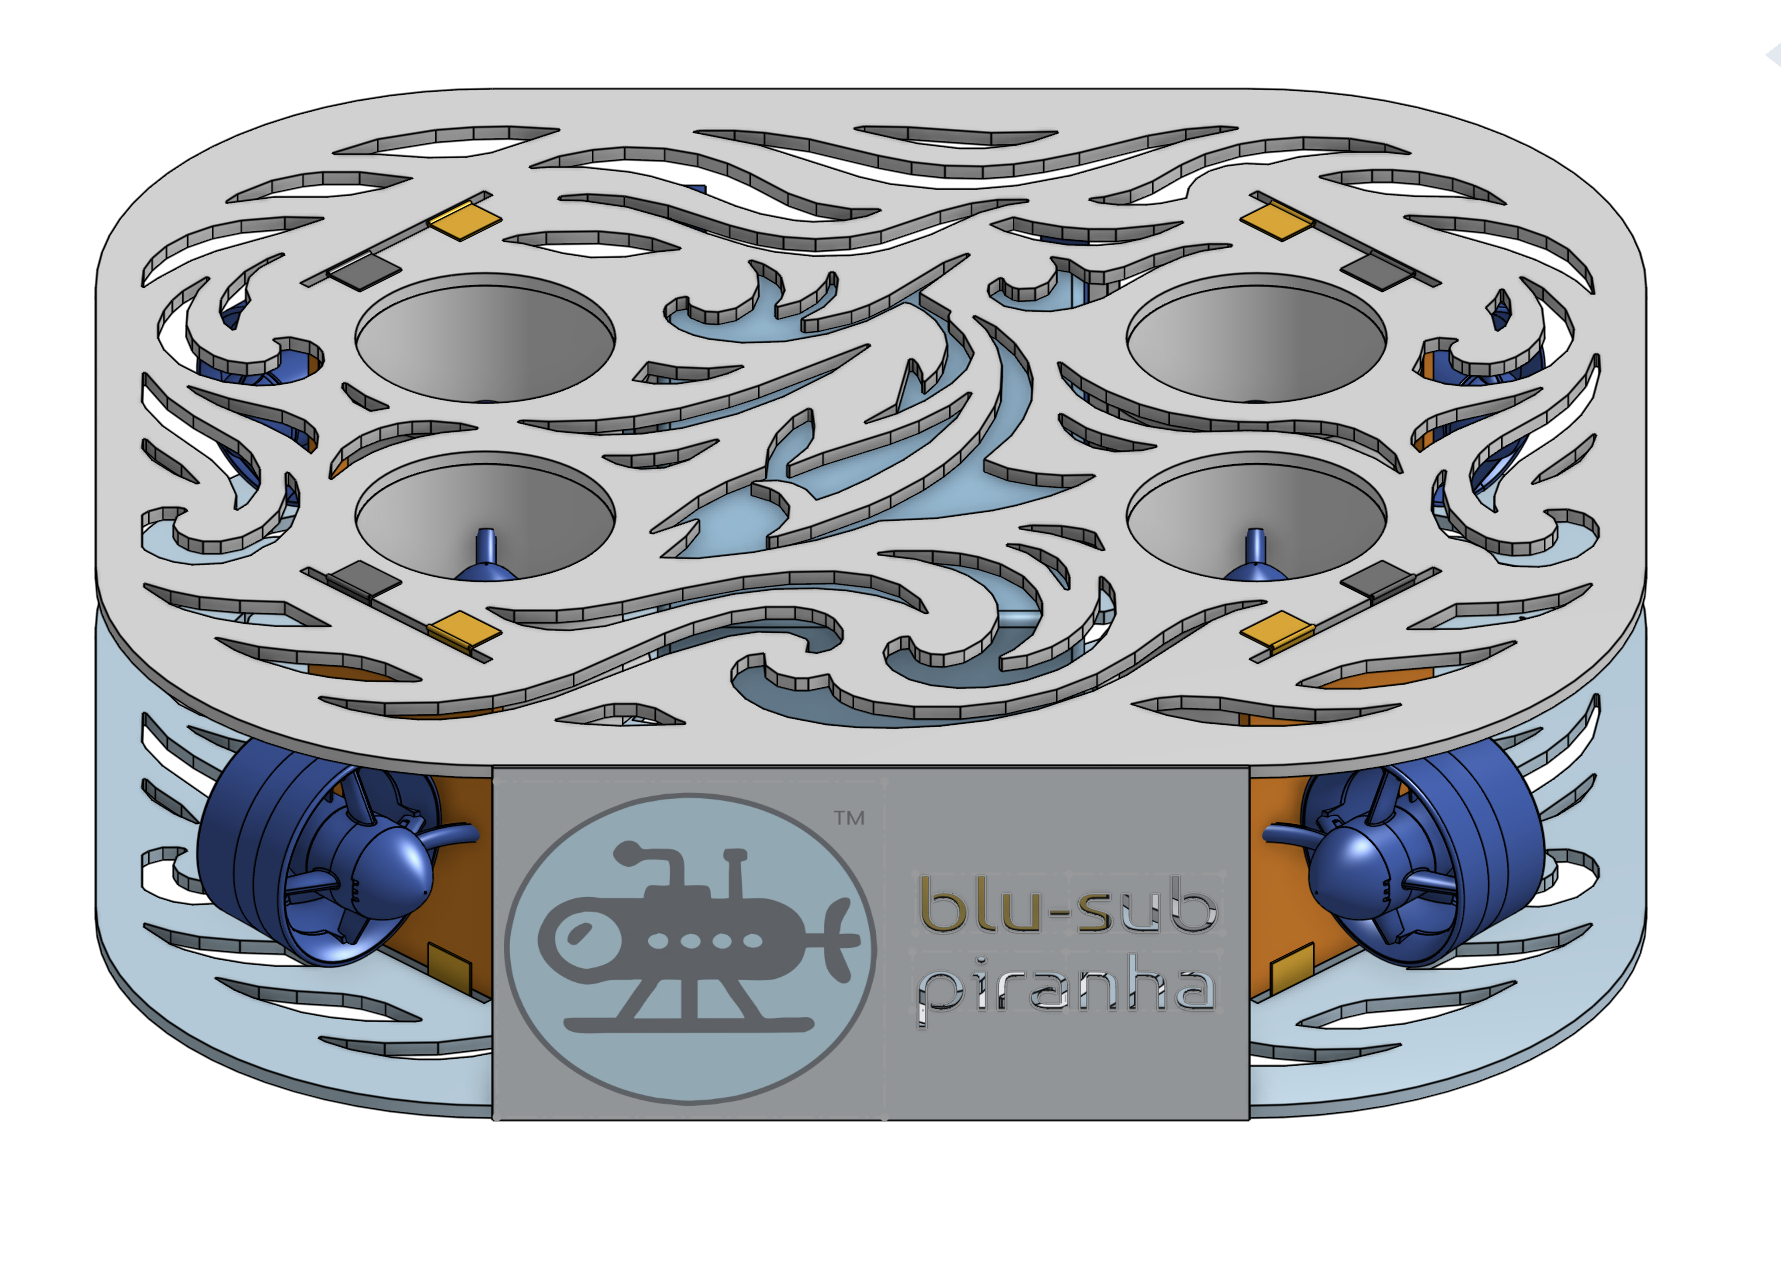
Propulsion — All eight thrusters are Blu-Sub units with built-in electronic speed controllers (ESCs), simplifying the wiring harness and giving direct, reliable thrust control on every channel. Four vertical thrusters handle depth and attitude, while four vectored horizontal thrusters cover planar translation and yaw.
Power — The vehicle is powered by two Blue Robotics lithium battery packs, providing the capacity and current delivery needed to run all eight thrusters plus the full electronics stack, with enough endurance for extended test runs.
Compute and sensing — The main pressure-rated enclosure houses a Jetson Orin Nano computer that runs the vehicle's autonomy stack. Perception comes from a forward-facing Intel RealSense camera for visual navigation and object detection, a bottom-facing Waterlinked DVL (Doppler Velocity Log) for accurate velocity-over-ground and position tracking, and a second bottom-facing USB camera for downward inspection and task verification.
Status — The vehicle is in active development: the mechanical layout, thruster configuration and electronics architecture are defined, with integration and pool testing under way.